Rithish Ramamoorthy Sathya — Robotics Research
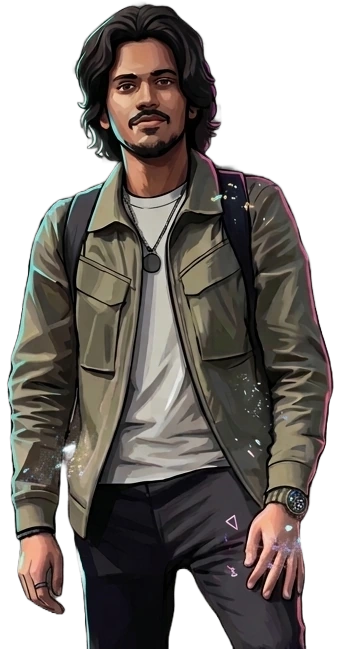
Portrait of Rithish Ramamoorthy Sathya

Rithish.

Building systems. Testing what transfers to the real world.

Research direction

  1. Perception that transfers.
  2. Memory that persists.
  3. Worlds to test in.

Core strengths

Robotics & perception

ROS 2 · SLAM · Sensor fusion

Machine vision

PyTorch · YOLO · SAM 3

Spatial representations

3D scene graphs · RGB-D · Scene memory

Simulation

Unity · Unreal Engine

Selected research

Further projects

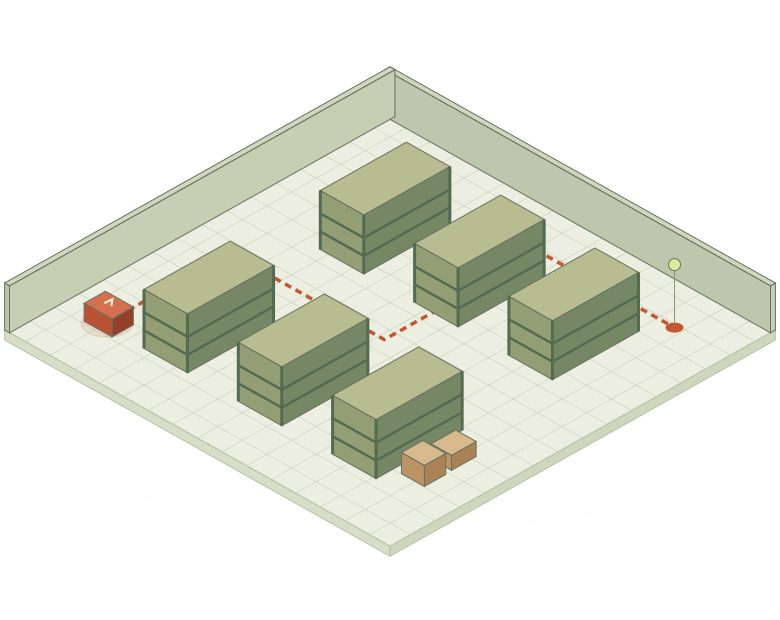
  1. TurtleBot navigating the twelve-zone beacon arena in Gazebo · 3× speed

    TurtleBot navigation

    2026

    ROS 2 · LiDAR SLAM · D* Lite

    Built a ROS 2 workflow connecting LiDAR mapping, D* Lite planning, and obstacle avoidance.

    Mapping to motion in Gazebo.

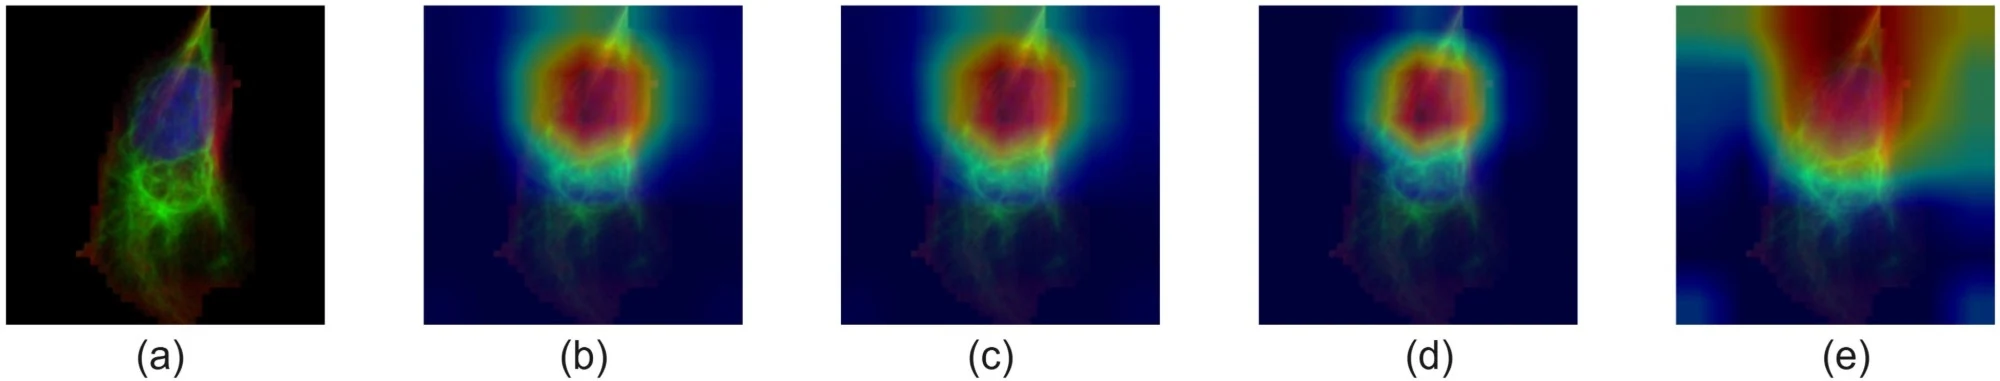
  2. A microscopy cell image, labelled (a), followed by its GradCAM (b), GradCAM++ (c), EigenCAM (d) and ScoreCAM (e) heatmaps.
    (a) original cell · (b) GradCAM · (c) GradCAM++ · (d) EigenCAM · (e) ScoreCAM

    Cancer Cell Classifier

    2026

    PyTorch · ResNet18 · DenseNet121 · XAI

    Trained ResNet18 and DenseNet121 and compared four visual explanation methods.

    97% / 94% accuracy for ResNet18 / DenseNet121.

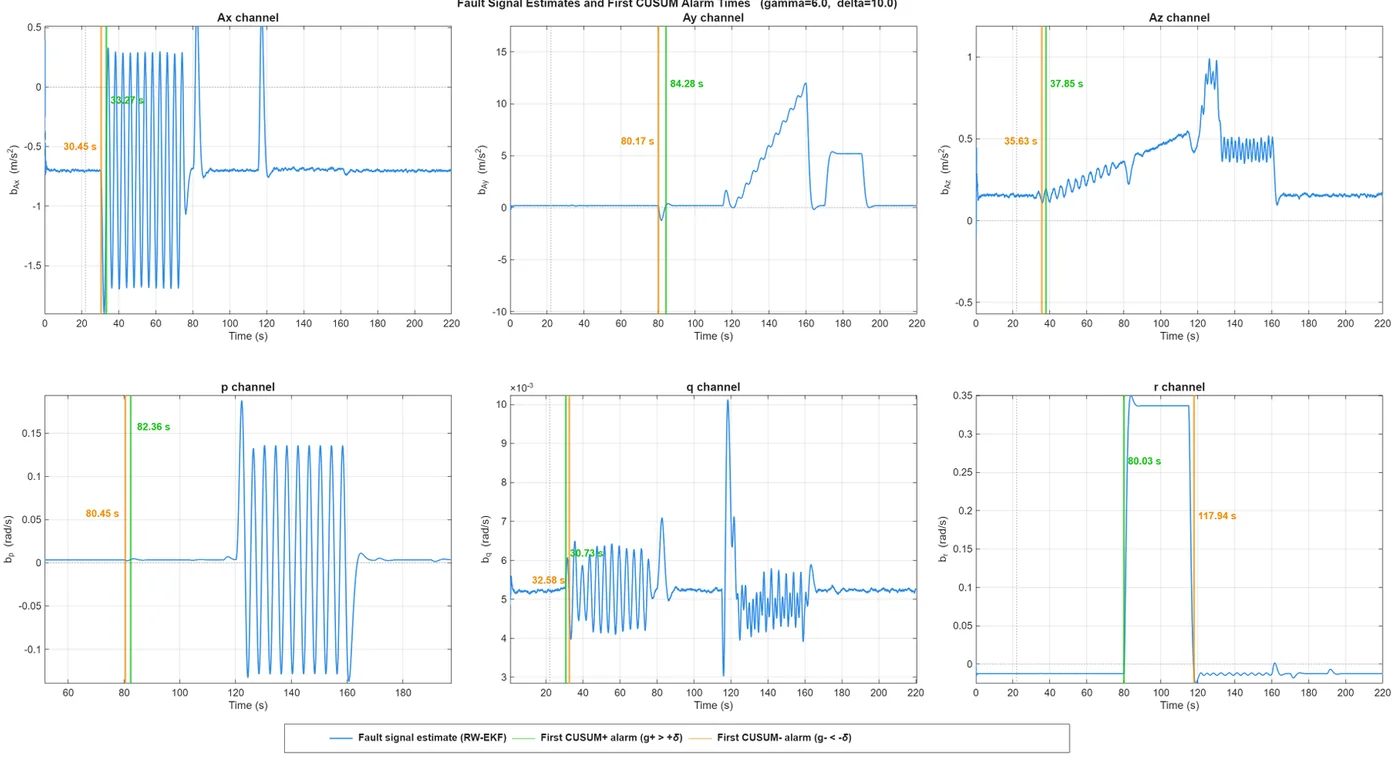
  3. Six inertial measurement channels with injected faults and the first CUSUM alarm marked on each.
    Injected faults and the first CUSUM alarm on each of six inertial channels

    Aircraft fault detection

    2026

    EKF · CUSUM · Latin hypercube search

    Combined an EKF, CUSUM monitoring, and a 200-point parameter search.

    False alarms cut from 105 to 0, with mean detection delay steady at about 56 s.

  4. BreadBot driving to the board with its pen end effector

    BreadBot

    2025

    Odometry · Finite-state control · 2-DoF arm

    Contributed to a mobile manipulator combining odometry, finite-state control, and a two-axis arm.

    Task completed in 1m 45s.

  5. Obstacle avoidance and object following, recorded side by side

    e-puck: avoid and follow

    2025

    IR sensing · Time-of-flight · State machines

    Contributed IR-based obstacle avoidance and ToF-based object-following behaviours on an e-puck.

    Two autonomous behaviours in a controlled arena.

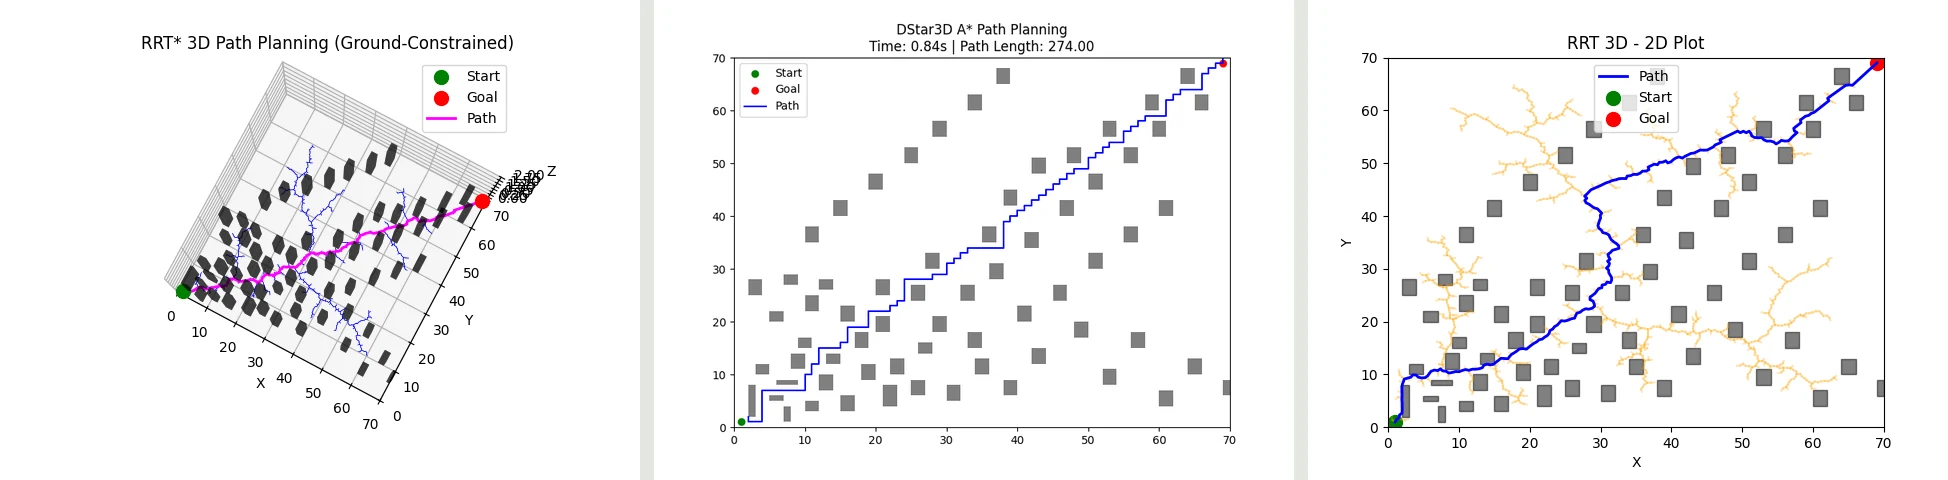
  6. Three planning views of the same procedurally generated terrain: an RRT* path over the 3D terrain, a D* path on the 2D grid, and an RRT tree seen from above.
    RRT* over 3D terrain · D* on the 2D grid · RRT tree, top view

    Planning on unknown terrain

    2025

    A* · RRT · RRT* · D* · Perlin terrain

    Compared A*, RRT, RRT*, and D* with partial knowledge of procedural terrain.

    D* was fastest on path-finding time.

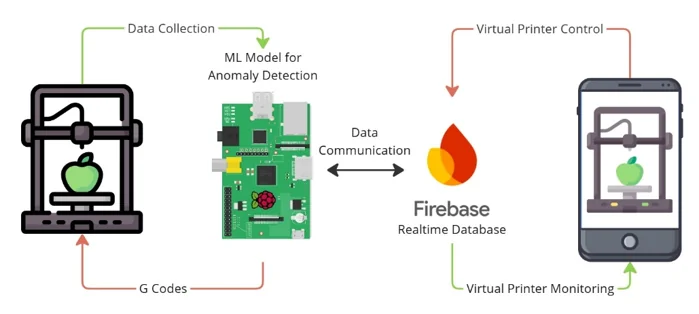
  7. System architecture: the printer and a Raspberry Pi running anomaly detection share data through a Firebase Realtime Database with a phone app for monitoring and control.
    Unity app mirroring the Ender 3 printer · system architecture

    A live digital twin

    2024

    Unity · Firebase · Random Forest · XGBoost

    Connected a physical FDM printer, Unity interface, and anomaly classifiers through live data.

    77% / 76% classification accuracy; associated paper accepted at ICAARS 2025.

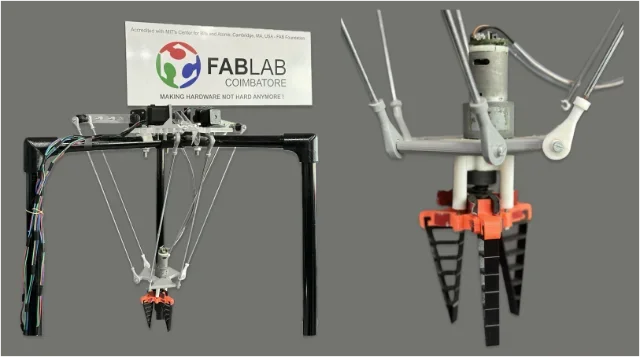
  8. The delta robot prototype and its 3D-printed end effector.
    The delta robot prototype and its 3D-printed end effector

    Vision-assisted delta robot

    2024

    RGB-D detection · PCB · Team of seven

    Led a seven-person team integrating RGB-D perception, electronics, and robot control for a pick-and-place MVP.

    93% detection accuracy.

Publications

  1. 2025

    Digital Twin based Real-Time Anomaly Detection for FDM Additive Manufacturing

    ICAARS 2025 · Advancements in Automation, Robotics & Sensing

    Conference paper · SpringerAccepted

  2. 2024

    Book chapter · IGI Global

  3. 2024

    Book chapter · Wiley Scrivener

  4. 2023

    Industry 5.0: Enhancing Human-Robot Collaboration through Collaborative Robots — A Review

    ICAECA 2023 · Advancements in Electrical, Electronics, Communication, Computing & Automation

    Conference paper · IEEE

  5. 2023

    Enhancing Human Cobot Interaction with Mixed Reality: A Futuristic Review

    ICAECA 2023 · Advancements in Electrical, Electronics, Communication, Computing & Automation

    Conference paper · IEEE

  6. 2023

    Collaboration of Mixed Reality for Interactive Visualization of Ocean Mapping

    ICAECA 2023 · Advancements in Electrical, Electronics, Communication, Computing & Automation

    Conference paper · IEEE

Toolkit

  • Robotics & perception

    ROS 2SLAMLocalisationSensor fusionEKFMulti‑sensor pipelinesrosbagRViz

  • Machine vision

    PyTorchTensorFlowOpenCVYOLOObject detectionSegmentationObject trackingRGB‑D processingPose estimationCamera calibrationDiffusion models, LoRAXAISAM 3SigLIPImage–text embeddings

  • Spatial intelligence

    3D scene graphsDepth back-projectionObject associationTemporal scene memory3D mapping and point clouds

  • Robot learning

    VLAsπ0 / π0.5NVIDIA GR00TOpenVLALeRobotData demands of policy trainingKnowledge only, no policy post-training.

  • Simulation & CAD

    Unreal EngineUnity 3DMuJoCoIsaac Sim (exploratory)Fusion 360XR (AR, MR, VR)

  • Programming

    PythonC++DockerLinuxGit

  • Agentic AI tools

    Claude CodeCodexOpenCodeLocal LLMs: Qwen, NemotronMulti-agent orchestrationLLMs and VLMs

  • Embedded & hardware

    Custom PCB wiring and solderingEmbedded controlSensor and actuator interfacing: encoders, ultrasonic, stepper motors, RGB‑DJetson NanoArduinoRaspberry Pi
Background

Expecting Distinction

Education

MSc Robotics

University of Sheffield

Sep 2025 — Sep 2026

Dissertation on physics-informed domain randomisation for underwater perception. Supervised by Jonathan Aitken.
Education

BE Mechatronics

Kumaraguru College of Technology · 7.9 / 10

Aug 2021 — Apr 2025

Thesis on 3D path planning in procedurally generated terrain.

Volunteer

Digital Innovation Zone Advisor

Siemens Excellence Centre, University of Sheffield

Oct 2025 — May 2026

UR5e operation and mentoring students in cobots, CAD, and fabrication.

Experience

Unity Developer · AR / AI Systems

Schnell Energy Equipments

Jul 2024 — Mar 2025

Real-time AR monitoring, computer vision, and live sensor visualisation.

Experience

Graduate Innovation Engineer

Forge Innovation & Ventures

Dec 2023 — Jun 2024

Innovation Fellow. Led a team of seven developing a vision-assisted robot MVP.

Experience

Unity Developer Internship

SatoriXR

Jul 2023 — Aug 2023

AR applications, immersive avatars, and Blender asset workflows.

Outside the lab

  • Hiking
  • Photography
  • Cinematography
  • Gaming

Let’s talk research.

Research collaborations, or an interesting robotics problem to work on together.

Rithish Ramamoorthy Sathya.

Research & project notes